mirror of
https://github.com/nerfstudio-project/nerfstudio.git
synced 2026-11-12 19:04:03 +08:00
Merge branch 'main' into cmk/ns_add_plotly
This commit is contained in:


5 files changed
+45
-18
No files matched your search
@@ -2,7 +2,7 @@
|
||||
|
||||
<h4> Biologically Plausible Neural Radiance Fields for View Synthesis</h4>
|
||||
|
||||
```{button-link} https://arxiv.org/pdf/2402.07310
|
||||
```{button-link} https://leandropassosjr.github.io/BioNeRF/
|
||||
:color: primary
|
||||
:outline:
|
||||
Paper Website
|
||||
@@ -19,7 +19,7 @@ Official Code
|
||||
:outline:
|
||||
Nerfstudio add-on code
|
||||
```
|
||||
<br>
|
||||
<br>
|
||||
|
||||
**Biologically Plausible Neural Radiance Fields**
|
||||
|
||||
@@ -43,7 +43,7 @@ ns-train bionerf --help
|
||||
|
||||
## Pipeline
|
||||
|
||||
<br>
|
||||
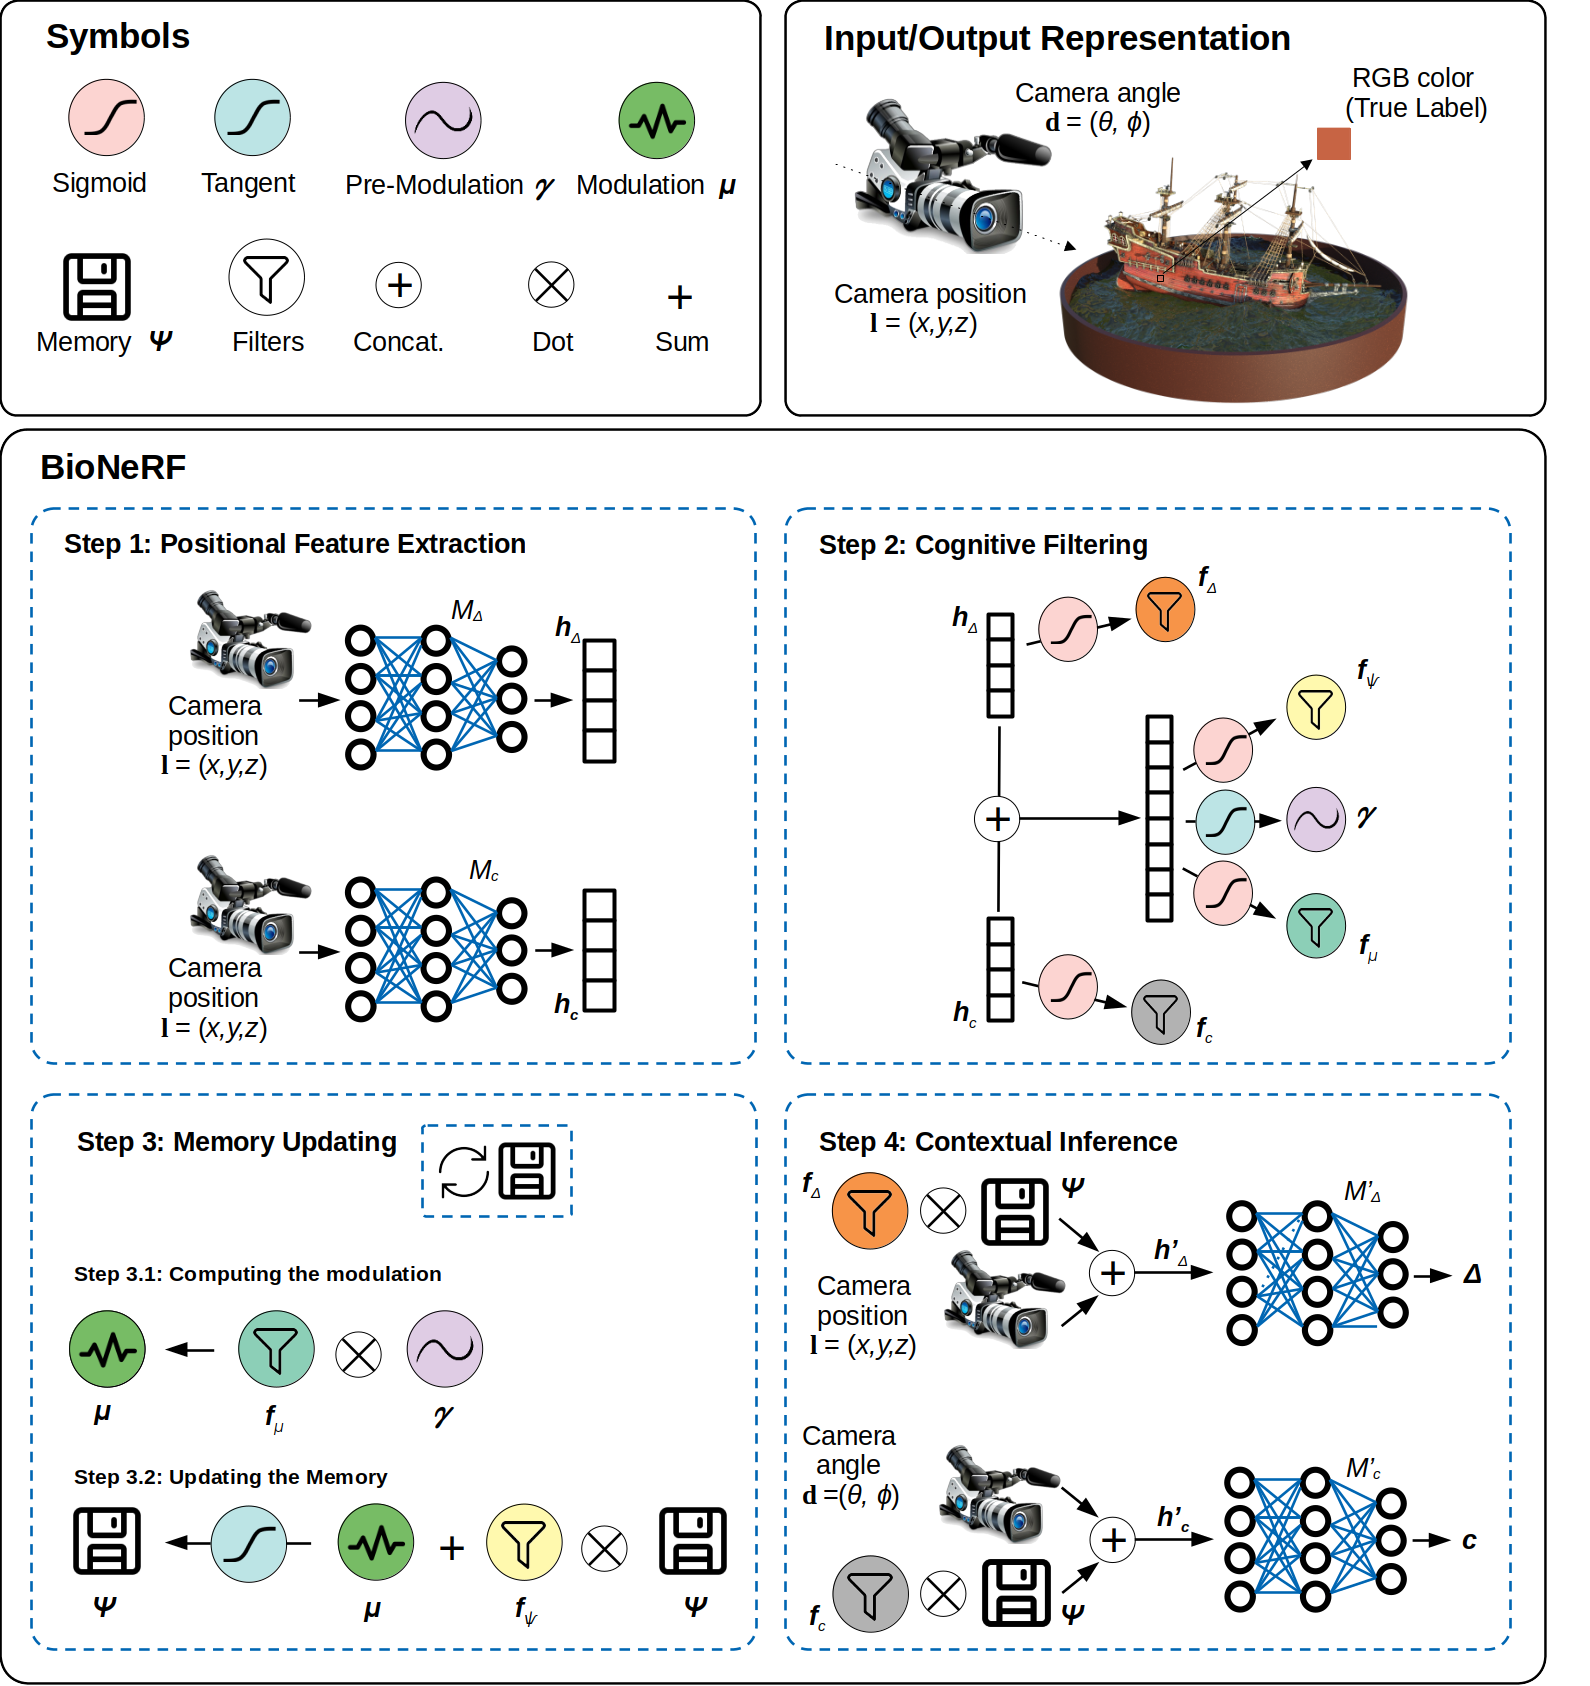<br>
|
||||
|
||||
Here is an overview pipeline for BioNeRF, we will walk through each component in this guide.
|
||||
|
||||
@@ -69,7 +69,7 @@ This step is responsible for adding contextual information to BioNeRF. Two new e
|
||||
| SSIM | 0.927 | 0.957 | 0.965 | 0.874 | 0.978 | 0.977 | 0.963 | 0.980 | 0.953 |
|
||||
| LPIPS | 0.047 | 0.018 | 0.017 | 0.068 | 0.018 | 0.011 | 0.016 | 0.010 | 0.026 |
|
||||
|
||||
<img src='https://leandropassosjr.github.io/BioNeRF/assets/blender.jpeg'/>
|
||||
<img src='https://leandropassosjr.github.io/BioNeRF/static/images/blender.jpeg'/>
|
||||
|
||||
Ground-truth (top) and synthetic view (bottom) images generated by BioNeRF regarding four Realistic Blender dataset’s scenes.
|
||||
|
||||
@@ -81,6 +81,6 @@ Ground-truth (top) and synthetic view (bottom) images generated by BioNeRF regar
|
||||
| SSIM | 0.837 | 0.873 | 0.914 | 0.882 | 0.796 | 0.714 | 0.911 | 0.911 | 0.861 |
|
||||
| LPIPS | 0.093 | 0.055 | 0.025 | 0.070 | 0.103 | 0.122 | 0.029 | 0.044 | 0.068 |
|
||||
|
||||
<img src='https://leandropassosjr.github.io/BioNeRF/assets/llff.jpeg'/>
|
||||
<img src='https://leandropassosjr.github.io/BioNeRF/static/images/llff.jpeg'/>
|
||||
|
||||
Ground-truth (top) and synthetic view (bottom) images generated by BioNeRF regarding four LLFF dataset’s scenes.
|
||||
@@ -339,6 +339,10 @@ def _undistort_image(
|
||||
) -> Tuple[np.ndarray, np.ndarray, Optional[torch.Tensor]]:
|
||||
mask = None
|
||||
if camera.camera_type.item() == CameraType.PERSPECTIVE.value:
|
||||
assert distortion_params[3] == 0, (
|
||||
"We doesn't support the 4th Brown parameter for image undistortion, "
|
||||
"Only k1, k2, k3, p1, p2 can be non-zero."
|
||||
)
|
||||
distortion_params = np.array(
|
||||
[
|
||||
distortion_params[0],
|
||||
|
||||
@@ -396,6 +396,10 @@ class PatchPixelSampler(PixelSampler):
|
||||
|
||||
config: PatchPixelSamplerConfig
|
||||
|
||||
def __init__(self, config: PatchPixelSamplerConfig, **kwargs) -> None:
|
||||
super().__init__(config, **kwargs)
|
||||
self.config.patch_size = self.kwargs.get("patch_size", self.config.patch_size)
|
||||
|
||||
def set_num_rays_per_batch(self, num_rays_per_batch: int):
|
||||
"""Set the number of rays to sample per batch. Overridden to deal with patch-based sampling.
|
||||
|
||||
|
||||
@@ -16,8 +16,9 @@
|
||||
|
||||
import csv
|
||||
import json
|
||||
import shutil
|
||||
from pathlib import Path
|
||||
from typing import Dict, List
|
||||
from typing import Dict, List, Optional
|
||||
|
||||
import numpy as np
|
||||
from PIL import Image
|
||||
@@ -29,10 +30,12 @@ from nerfstudio.utils.rich_utils import CONSOLE
|
||||
def realitycapture_to_json(
|
||||
image_filename_map: Dict[str, Path],
|
||||
csv_filename: Path,
|
||||
ply_filename: Optional[Path],
|
||||
output_dir: Path,
|
||||
verbose: bool = False,
|
||||
) -> List[str]:
|
||||
"""Convert RealityCapture data into a nerfstudio dataset.
|
||||
See https://dev.epicgames.com/community/learning/knowledge-base/vzwB/capturing-reality-realitycapture-xmp-camera-math
|
||||
|
||||
Args:
|
||||
image_filenames: List of paths to the original images.
|
||||
@@ -73,18 +76,19 @@ def realitycapture_to_json(
|
||||
frame["h"] = int(height)
|
||||
frame["w"] = int(width)
|
||||
frame["file_path"] = image_filename_map[basename].as_posix()
|
||||
frame["fl_x"] = float(cameras["f"][i]) * max(width, height) / 36
|
||||
frame["fl_y"] = float(cameras["f"][i]) * max(width, height) / 36
|
||||
# TODO: Unclear how to get the principal point from RealityCapture, here a guess...
|
||||
frame["cx"] = float(cameras["px"][i]) / 36.0 + width / 2.0
|
||||
frame["cy"] = float(cameras["py"][i]) / 36.0 + height / 2.0
|
||||
# TODO: Not sure if RealityCapture uses this distortion model
|
||||
frame["k1"] = cameras["k1"][i]
|
||||
frame["k2"] = cameras["k2"][i]
|
||||
frame["k3"] = cameras["k3"][i]
|
||||
frame["k4"] = cameras["k4"][i]
|
||||
frame["p1"] = cameras["t1"][i]
|
||||
frame["p2"] = cameras["t2"][i]
|
||||
# reality capture uses the 35mm equivalent focal length
|
||||
# See https://en.wikipedia.org/wiki/35_mm_equivalent_focal_length
|
||||
scale = max(width, height)
|
||||
frame["fl_x"] = float(cameras["f"][i]) * scale / 36.0
|
||||
frame["fl_y"] = float(cameras["f"][i]) * scale / 36.0
|
||||
frame["cx"] = float(cameras["px"][i]) * scale + width / 2.0
|
||||
frame["cy"] = float(cameras["py"][i]) * scale + height / 2.0
|
||||
frame["k1"] = float(cameras["k1"][i])
|
||||
frame["k2"] = float(cameras["k2"][i])
|
||||
frame["k3"] = float(cameras["k3"][i])
|
||||
frame["k4"] = float(cameras["k4"][i])
|
||||
frame["p1"] = float(cameras["t1"][i])
|
||||
frame["p2"] = float(cameras["t2"][i])
|
||||
|
||||
# Transform matrix to nerfstudio format. Please refer to the documentation for coordinate system conventions.
|
||||
rot = _get_rotation_matrix(-float(cameras["heading"][i]), float(cameras["pitch"][i]), float(cameras["roll"][i]))
|
||||
@@ -97,6 +101,10 @@ def realitycapture_to_json(
|
||||
frames.append(frame)
|
||||
data["frames"] = frames
|
||||
|
||||
if ply_filename is not None:
|
||||
shutil.copy(ply_filename, output_dir / "sparse_pc.ply")
|
||||
data["ply_file_path"] = "sparse_pc.ply"
|
||||
|
||||
with open(output_dir / "transforms.json", "w", encoding="utf-8") as f:
|
||||
json.dump(data, f, indent=4)
|
||||
|
||||
|
||||
@@ -336,6 +336,9 @@ class ProcessRealityCapture(BaseConverterToNerfstudioDataset, _NoDefaultProcessR
|
||||
2. Converts RealityCapture poses into the nerfstudio format.
|
||||
"""
|
||||
|
||||
ply: Optional[Path] = None
|
||||
"""Path to the RealityCapture exported ply file"""
|
||||
|
||||
num_downscales: int = 3
|
||||
"""Number of times to downscale the images. Downscales by 2 each time. For example a value of 3
|
||||
will downscale the images by 2x, 4x, and 8x."""
|
||||
@@ -353,6 +356,12 @@ class ProcessRealityCapture(BaseConverterToNerfstudioDataset, _NoDefaultProcessR
|
||||
if self.eval_data is not None:
|
||||
raise ValueError("Cannot use eval_data since cameras were already aligned with RealityCapture.")
|
||||
|
||||
if self.ply is not None:
|
||||
if self.ply.suffix != ".ply":
|
||||
raise ValueError(f"PLY file {self.ply} must have a .ply extension")
|
||||
if not self.ply.exists():
|
||||
raise ValueError(f"PLY file {self.ply} doesn't exist")
|
||||
|
||||
self.output_dir.mkdir(parents=True, exist_ok=True)
|
||||
image_dir = self.output_dir / "images"
|
||||
image_dir.mkdir(parents=True, exist_ok=True)
|
||||
@@ -390,7 +399,9 @@ class ProcessRealityCapture(BaseConverterToNerfstudioDataset, _NoDefaultProcessR
|
||||
realitycapture_utils.realitycapture_to_json(
|
||||
image_filename_map=image_filename_map,
|
||||
csv_filename=self.csv,
|
||||
ply_filename=self.ply,
|
||||
output_dir=self.output_dir,
|
||||
verbose=self.verbose,
|
||||
)
|
||||
)
|
||||
|
||||
|
||||
Reference in new issue
Block a user