```{button-link} https://haithemturki.com/pynerf/
:color: primary
:outline:
Paper Website
```
```{button-link} https://github.com/hturki/pynerf
:color: primary
:outline:
Code
```
**A fast NeRF anti-aliasing strategy.**
## Installation
First, install Nerfstudio and its dependencies. Then install the PyNeRF extension and [torch-scatter](https://github.com/rusty1s/pytorch_scatter):
```
pip install git+https://github.com/hturki/pynerf
pip install torch-scatter -f https://data.pyg.org/whl/torch-${TORCH_VERSION}+${CUDA}.html
```
## Running PyNeRF
There are three default configurations provided which use the MipNeRF 360 and Multicam dataparsers by default. You can easily use other dataparsers via the ``ns-train`` command (ie: ``ns-train pynerf nerfstudio-data --data `` to use the Nerfstudio data parser)
The default configurations provided are:
| Method | Description | Scene type | Memory |
| ----------------------- |---------------------------------------------------| ------------------------------ |--------|
| `pynerf ` | Tuned for outdoor scenes, uses proposal network | outdoors | ~5GB |
| `pynerf-synthetic` | Tuned for synthetic scenes, uses proposal network | synthetic | ~5GB |
| `pynerf-occupancy-grid` | Tuned for Multiscale blender, uses occupancy grid | synthetic | ~5GB |
The main differences between them is whether they are suited for synthetic/indoor or real-world unbounded scenes (in case case appearance embeddings and scene contraction are enabled), and whether sampling is done with a proposal network (usually better for real-world scenes) or an occupancy grid (usally better for single-object synthetic scenes like Blender).
## Method
Most NeRF methods assume that training and test-time cameras capture scene content from a roughly constant distance:
They degrade and render blurry views in less constrained settings:
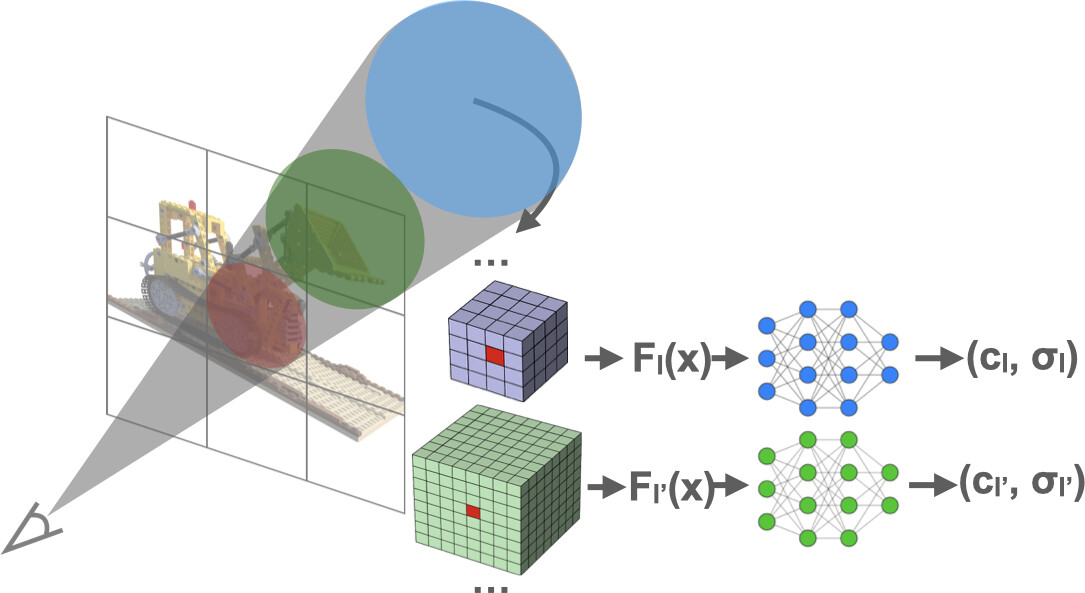
This is due to NeRF being scale-unaware, as it reasons about point samples instead of volumes. We address this by training a pyramid of NeRFs that divide the scene at different resolutions. We use "coarse" NeRFs for far-away samples, and finer NeRF for close-up samples: